Projects

Selected work across robotics, vision, and iOS. Proof-forward, detail-rich, and iterated in public.

Focus areas

  • Robotics
  • Autonomy
  • Computer Vision
  • iOS Systems
  • Embedded Controls

Latest release

PALA V1: a five-axis desk companion with Gemini observations, local Python choreography, and Jetson / PCA9685 control.

Collaboration

Open to early-stage prototypes, field tests, and systems design partnerships that need quick iteration and clear proof points.

How I build

Each project focuses on tangible outcomes: system architecture, measurable performance, and a documented path to the next iteration.

System-first planning

Define interfaces and constraints early so software, hardware, and controls stay aligned through integration.

Prototype โ†’ proof

Ship working demos quickly, then pressure-test assumptions with real data, metrics, and usability feedback.

Documented iteration

Capture architecture decisions, experiment results, and next steps so progress stays visible and repeatable.

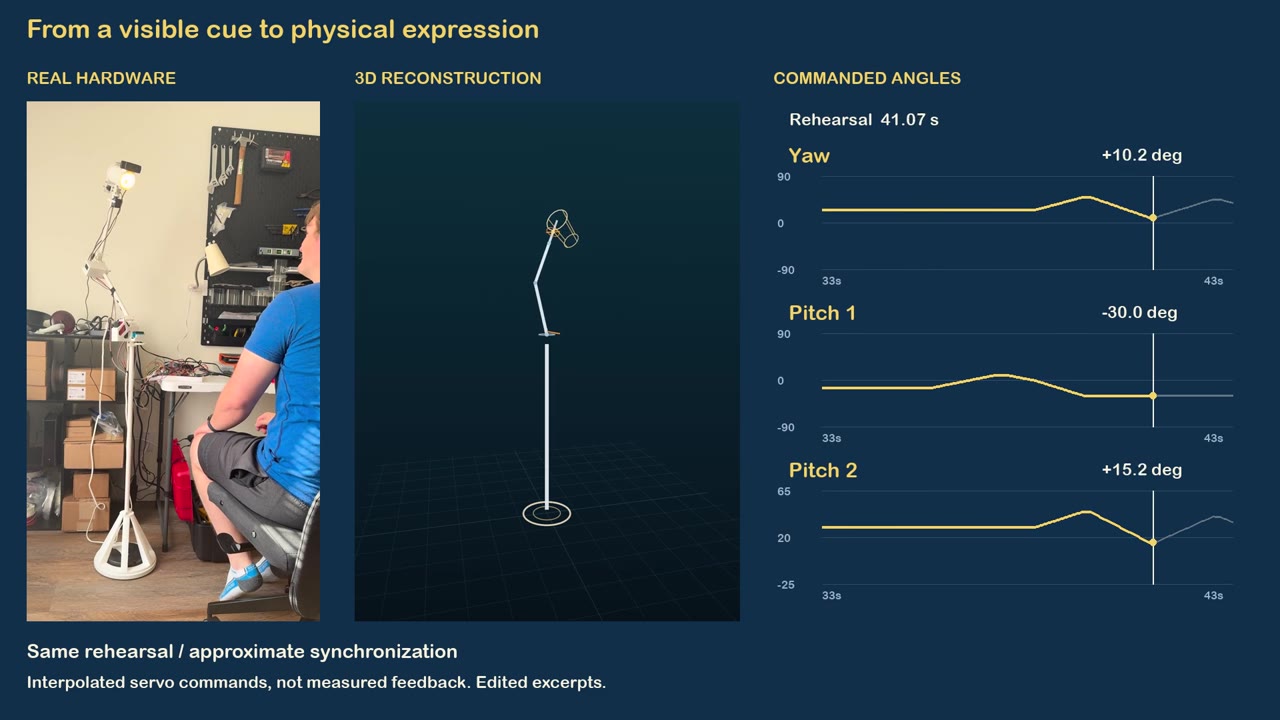
PALA's physical lamp alongside a motion reconstruction and commanded joint angles

Completed V1 ยท September 2026

PALA โ€” An expressive desk companion

A five-axis lamp that notices, greets, celebrates a thumbs-up, and settles into a breathing rest pose.

  • Built: custom printed mechanisms + camera-driven choreography
  • Stack: Jetson, Python, PCA9685, Gemini
  • Outcome: supervised V1 demo + documented architecture

Video Fit AI

Workout tracking via on-device video analysis and Gemini video APIs.

  • Built: Swift iOS camera pipeline + Vapor backend
  • Stack: iOS AVFoundation, Gemini, Vapor
  • Outcome: end-to-end prototype + architecture writeup

Pose Estimation Pipeline

Fast pose inference for real-time feedback on mobile.

  • Built: optimized inference + data capture tooling
  • Stack: Core ML, Python tooling, iOS
  • Outcome: on-device prototype targeting real-time performance