Dylan Duecaster

Systems Engineer → Robotics / Autonomy / iOS + Vision

I build systems at the intersection of robotics, computer vision, and mobile. My work spans embedded hardware, AI pipelines, and iOS experiences that I prototype and iterate toward real-world use.

Latest release: PALA V1, a working expressive desk companion.

Featured Projects

Proof-oriented work with clear scope and measurable progress.

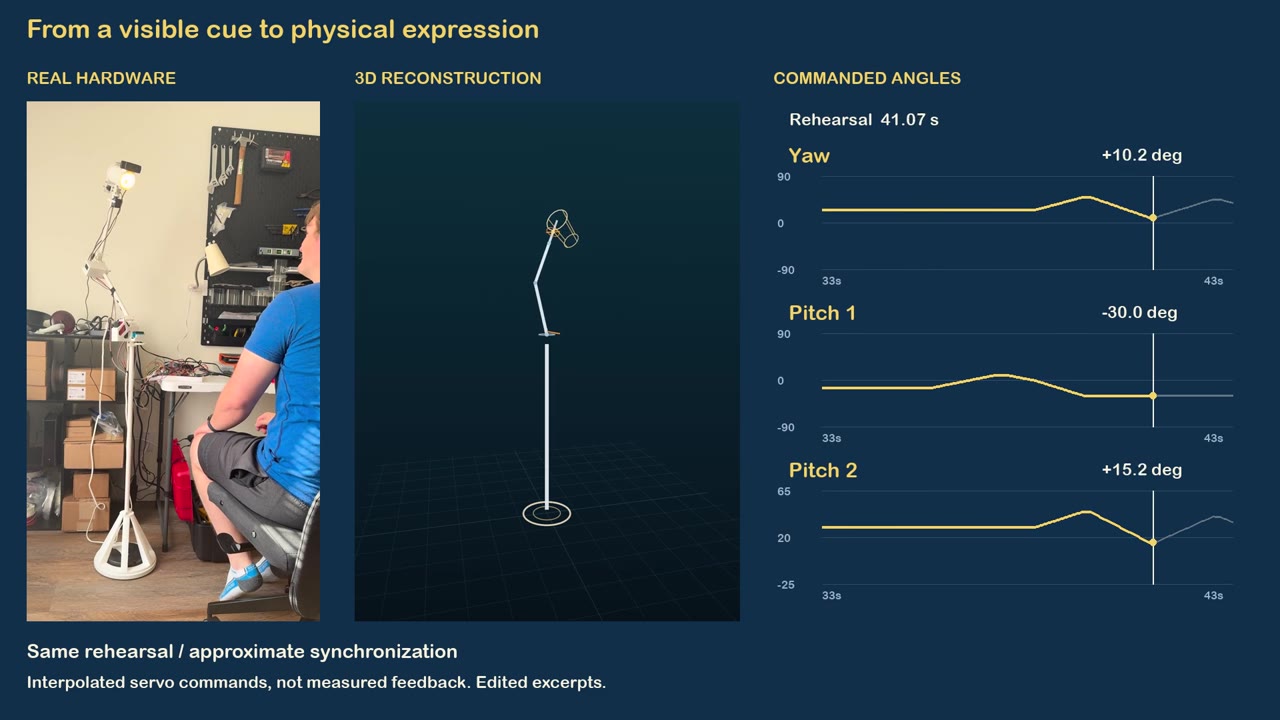
PALA's physical lamp alongside a motion reconstruction and commanded joint angles

Completed V1 · September 2026

PALA — An expressive desk companion

A five-axis lamp that notices, greets, celebrates a thumbs-up, and settles into a breathing rest pose.

  • Built: custom printed mechanisms + camera-driven choreography
  • Stack: Jetson, Python, PCA9685, Gemini
  • Outcome: supervised V1 demo + documented architecture

Video Fit AI

Workout tracking via on-device video analysis and Gemini video APIs.

  • Built: Swift iOS camera pipeline + Vapor backend
  • Stack: iOS AVFoundation, Gemini, Vapor
  • Outcome: end-to-end prototype + architecture writeup

Pose Estimation Pipeline

Fast pose inference for real-time feedback on mobile.

  • Built: optimized inference + data capture tooling
  • Stack: Core ML, Python tooling, iOS
  • Outcome: on-device prototype targeting real-time performance
M.S. Aero (Purdue)
Systems Engineer @ Boeing
Vision + Pose Estimation
Embedded STM32 + Jetson
iOS + SwiftUI

Writing / Build Logs

Latest notes on systems, vision, and iterative builds.

About

I am an aerospace engineer by training (B.S. + M.S. at Purdue University) and currently a systems engineer at Boeing. My strength is in systems thinking, integration, and design engineering—translating high‑level requirements into implementable technical solutions. I am increasingly focused on bridging traditional systems engineering with software‑heavy, autonomy‑driven products.

Outside of work, I build end‑to‑end systems that combine software, hardware, and applied AI. My projects emphasize real‑world constraints, integration challenges, and measurable outcomes rather than isolated demos. Key interests include robotics, autonomy, embedded systems, computer vision, and iOS as a user‑facing control layer.

I value clean architecture, thoughtful tradeoffs, and systems that are reliable and maintainable. The goal for this portfolio is evidence: clear demonstrations of how I think, what I build, and how I approach complex systems.